রোবটগুলো: Int-Ball2 আর Astrobee
এই পাতা সম্পর্কেশেখার পথ · সূচিপত্র
Kibo-RPC-তে তুমি যে প্রোগ্রাম লিখবে, সেটা চালাবে মহাকাশ স্টেশনের ভেতরের একটা আসল রোবট। ৭ম Kibo-RPC-র রোবট হলো JAXA-র (জাপানের মহাকাশ সংস্থা) Int-Ball2; আগের ছয়বারের রোবট ছিল NASA-র (যুক্তরাষ্ট্রের মহাকাশ সংস্থা) Astrobee। এই পাতায় দেখবে রোবটগুলো দেখতে কেমন, কীভাবে ভেসে ভেসে চলে, আর কীভাবে নিজের পথ চেনে।
The robots: Int-Ball2 and Astrobee
About this pageLearning path · contents
The program you write for Kibo-RPC runs on a real robot inside the space station. The 7th Kibo-RPC robot is JAXA's (Japan's space agency) Int-Ball2; for the six before it, the robot was NASA's (the US space agency) Astrobee. This page shows what the robots look like, how they float and move, and how they find their way.
3D মডেলগুলো প্রকাশিত বর্ণনা আর ছবি দেখে বানানো সহজ নকশা, অফিশিয়াল CAD মডেল নয়; মাপগুলো মোটামুটি অনুপাতে। রঙের মানে: ক্যামেরা সেন্সর আর মস্তিষ্ক চলাফেরা আর শক্তি বডি আর মানুষের সঙ্গে যোগাযোগ
The 3D models are simplified sketches built from the published descriptions and diagrams, not official CAD models; sizes are only roughly to scale. Colours: camera sensing & brain moving & power body & people
১. মহাকাশ স্টেশন আর Kibo
আন্তর্জাতিক মহাকাশ স্টেশন (ইংরেজিতে ISS) পৃথিবী থেকে প্রায় ৪০০ কিলোমিটার ওপরে ঘুরছে: ঢাকা থেকে কক্সবাজার যতটা দূর, মোটামুটি ততটা ওপরে। প্রায় দেড় ঘণ্টায় এটা একবার পুরো পৃথিবী ঘুরে আসে।
স্টেশনের ভেতরে নভোচারীরা থাকেন আর বিজ্ঞানের নানা পরীক্ষা করেন। স্টেশনটা অনেকগুলো ঘর জোড়া দিয়ে বানানো; প্রতিটা ঘরকে বলে মডিউল। জাপানের মডিউলটার নাম Kibo (জাপানি ভাষায় মানে “আশা”): লম্বা নলের মতো একটা ঘর, ভেতরটা মোটামুটি একটা বাসের সমান। রোবট উড়ে বেড়ায় এর ভেতরেই।
- ISS
- International Space Station, আন্তর্জাতিক মহাকাশ স্টেশন।
- মডিউল
- স্টেশনের একেকটা ঘর। Kibo জাপানের মডিউল।
- নভোচারী
- মহাকাশে যাওয়া মানুষ (অ্যাস্ট্রোনট)।
২. ভেসে থাকা রোবট কীভাবে চলে
স্টেশনের ভেতরে সবকিছু ভাসে: কলম, পানির ফোঁটা, মানুষও। কারণ স্টেশন আর তার ভেতরের সবকিছু একসঙ্গে পৃথিবীর চারদিকে “পড়ছে”, কেউ কারও চেয়ে জোরে পড়ছে না, তাই মনে হয় কারও ওজন নেই। একে বলে মাইক্রোগ্র্যাভিটি (প্রায় শূন্য মাধ্যাকর্ষণ)।
তাহলে রোবট চলে কীভাবে? চাকা কাজ করবে না, কারণ ভাসমান রোবট মেঝেই ছোঁয় না! বেলুনের কথা ভাবো: ফুলিয়ে মুখটা ছেড়ে দিলে বাতাস পেছন দিয়ে বেরোয়, আর বেলুন ছোটে সামনে।
Int-Ball2-ও তাই করে: এর ভেতরের ছোট ছোট পাখা বাতাস এক দিকে ঠেলে দেয়, আর রোবট সরে যায় উল্টো দিকে। আলাদা আলাদা পাখা চালিয়ে রোবট যেকোনো দিকে সরতে আর ঘুরতে পারে।
আরেকটা মজার ব্যাপার: একবার চলতে শুরু করলে রোবট নিজে থেকে প্রায় থামেই না; থামাতে হলে উল্টো দিকে ঠেলতে হয়। মুক্ত ফ্লাইট পাতায় Zero-g চালু করে নিজে অনুভব করে দেখো!
মহাকাশ স্টেশনে চাকাওয়ালা রোবট কেন চলতে পারবে না?
চাকা ঘুরে মেঝেতে চাপ দিয়ে এগোয়। কিন্তু ভাসমান রোবট মেঝে ছোঁয় না, তাই চাকা শুধু শূন্যে ঘুরবে।
রোবটকে বাঁয়ে সরাতে পাখাগুলো বাতাস কোন দিকে ঠেলবে?
ডানে। বাতাস যেদিকে যায়, রোবট যায় তার উল্টো দিকে।
৩. রোবট কীভাবে দেখে আর পথ চেনে
চোখ বন্ধ করে ঘরের ভেতর হাঁটলে তুমি আন্দাজ করো কতটা হাঁটলে আর কতটা ঘুরলে। চোখ খুললে চেনা জিনিস (বোর্ড, জানালা) দেখে নিশ্চিত হও ঠিক কোথায় আছ। Int-Ball2-ও ঠিক এভাবেই নিজের জায়গা বোঝে:
- IMU (চোখ বন্ধ করে আন্দাজ): ছোট্ট একটা সেন্সর, যেটা টের পায় রোবট কতটা ঘুরছে আর কতটা জোরে গতি বাড়াচ্ছে বা কমাচ্ছে। তোমার কানের ভেতরে ভারসাম্য বোঝার যে অংশ আছে, অনেকটা সেরকম।
- স্টেরিও ক্যামেরা (চোখ খুলে দেখা): পাশাপাশি দুটো ক্যামেরা, তোমার দুই চোখের মতো। দুই চোখে দেখলে বোঝা যায় কোন জিনিস কত দূরে। রোবট এগুলো দিয়ে মডিউলের একটা ম্যাপ বানায়, আর সেই ম্যাপে নিজেকে খুঁজে নেয়।
- মূল ক্যামেরা: সামনের দিকের ক্যামেরা, যেটা ছবি আর ভিডিও তোলে। Kibo-RPC-তে এটা দিয়েই AR মার্কার পড়তে হয়।
AR মার্কার দেখতে QR কোডের মতো সাদাকালো চৌকো ছবি। প্রতিটায় একটা নম্বর (ID) লুকানো থাকে, আর ক্যামেরার ছবি থেকে হিসাব করা যায় মার্কারটা কত দূরে আর কোন দিকে। Kibo-র ভেতরে এমন ১২টা মার্কার লাগানো আছে।
IMU আর স্টেরিও ক্যামেরা মিলিয়ে রোবট সবসময় জানে সে কোথায় আছে আর কোন দিকে মুখ করে আছে। “কোথায়” আর “কোন দিকে” কীভাবে সংখ্যায় লেখা হয়, তা শিখবে শেখার পথের পরের ধাপে: স্থানাঙ্ক ও ঘূর্ণন।
IMU কী টের পায়?
রোবট কতটা ঘুরছে, আর কতটা জোরে গতি বাড়াচ্ছে বা কমাচ্ছে।
পাশাপাশি দুটো ক্যামেরা থাকলে কী সুবিধা?
কোন জিনিস কত দূরে, তা বোঝা যায়, ঠিক আমাদের দুই চোখের মতো।
Kibo-RPC-তে AR মার্কার পড়তে কোন ক্যামেরা লাগে?
মূল ক্যামেরা, যেটা রোবটের সামনের দিকে।
Int-Ball2 (JAXA)
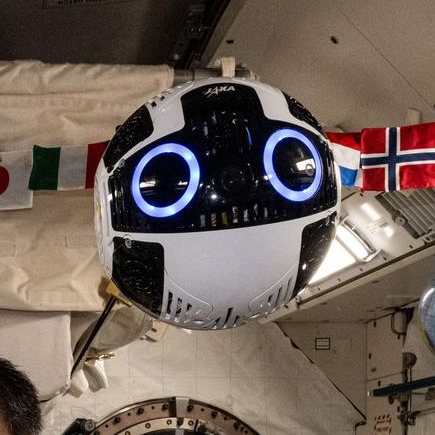
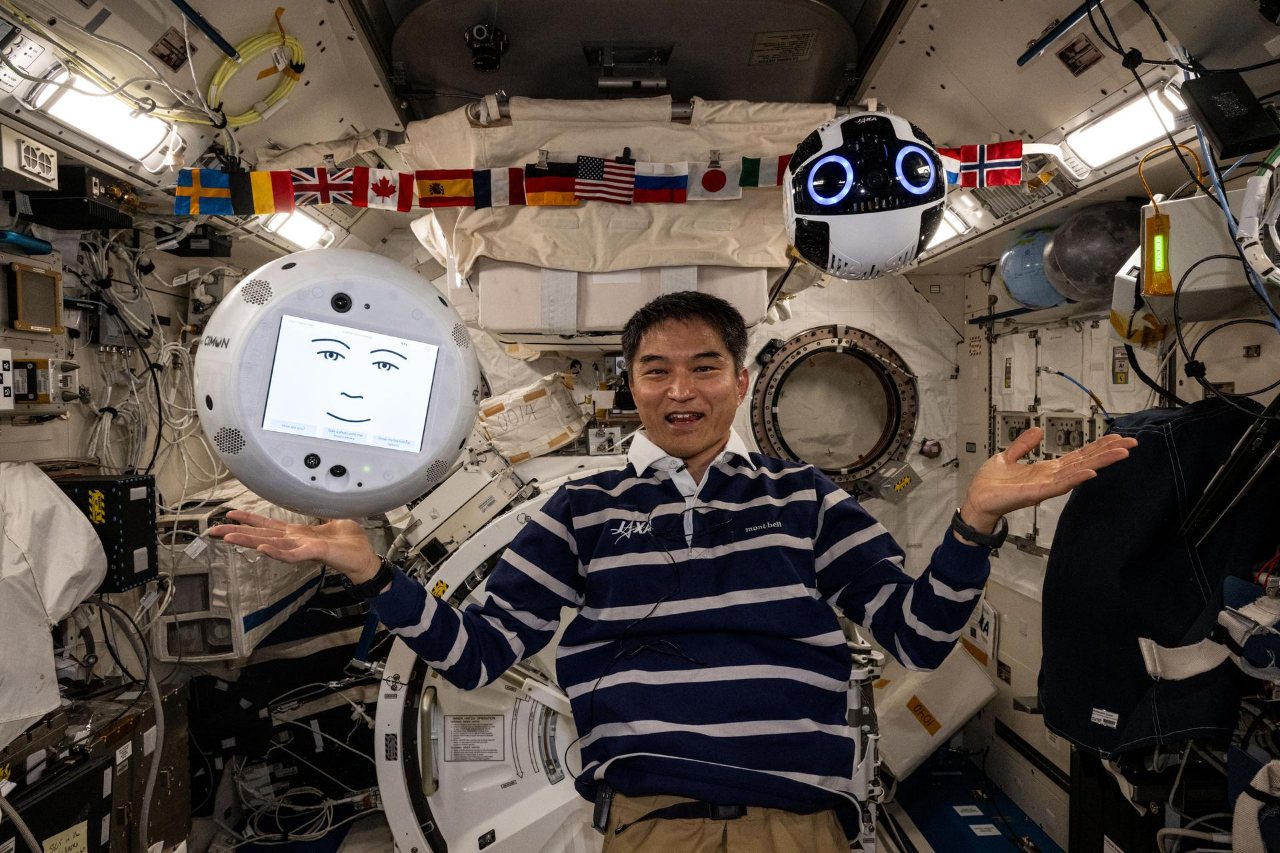
Int-Ball2 (JEM Internal Ball Camera 2) বলের মতো গোল একটা উড়ুক্কু ক্যামেরা রোবট, আকারে মোটামুটি একটা ফুটবলের সমান; ২০২৩ সালের জুন থেকে Kibo-র ভেতরে কাজ করছে। মাটি থেকে কন্ট্রোলাররা এটা উড়িয়ে ছবি আর ভিডিও তোলেন, যাতে নভোচারীদের ক্যামেরা হাতে কম সময় কাটাতে হয়। এটা অন্য দলের লেখা প্রোগ্রামও চালাতে পারে; Kibo-RPC 7-এর প্রোগ্রাম এভাবেই কক্ষপথে পৌঁছায়।
সামনে
পেছনে
| আকার | মোটামুটি ২০ সেমি চওড়া একটা বল |
|---|---|
| ভর | প্রায় ৩.৩ কেজি |
| চলে যা দিয়ে | নালির ভেতরে বসানো ৮টা ছোট প্রপেলার, কোণাকুণি বাইরের দিকে মুখ করা; অর্ধেক ঘোরে ঘড়ির কাঁটার দিকে, অর্ধেক উল্টো দিকে। সব মিলিয়ে এরা রোবটকে যেকোনো দিকে ঠেলতে আর ঘোরাতে পারে (একে বলে ৬ ডিগ্রি অব ফ্রিডম: তিন দিকে সরা, আর তিন রকম ঘোরা)। |
| সবচেয়ে জোরালো ঠেলা | সামনে বা পেছনে ১৫৫ mN, ওপরে বা নিচে ৯৫ mN, পাশে ৫৭ mN (মেপে দেখা; mN, মানে মিলিনিউটন, হলো বলের একক)। পৃথিবীতে ১৬ গ্রামের একটা জিনিসের ওজন মোটামুটি এতটুকু, তিনটা A4 কাগজের মতো। তাই এটা ধীরেসুস্থে গতি বাড়ায় আর থামে। |
| ক্যামেরা | সামনে ছবি আর ভিডিওর জন্য মূল ক্যামেরা। পথ চেনার জন্য স্টেরিও ক্যামেরা (দুটো লেন্স)। |
| নিজের অবস্থান বোঝে | (সহজ কথায় ৩ নম্বর অংশে) স্টেরিও ক্যামেরায় ভিজ্যুয়াল SLAM দিয়ে (মডিউলের ম্যাপ বানায় আর সেই ম্যাপে নিজেকে খুঁজে নেয়), সঙ্গে একটা IMU (Epson-এর ইনারশিয়াল মেজারমেন্ট ইউনিট: জাইরোস্কোপ আর অ্যাক্সেলেরোমিটার)। |
| মস্তিষ্ক | Linux আর ROS চালানো একটা NVIDIA Jetson TX2। ইউজারদের প্রোগ্রাম চলে Docker কন্টেইনারে, ওড়ার সফটওয়্যার থেকে আলাদা হয়ে। |
| শক্তি | রিচার্জেবল ব্যাটারি; চার্জ নিতে নিজেই ডকিং স্টেশনে গিয়ে বসে। |
| মানুষের সঙ্গে | নিজের অবস্থা বোঝাতে দুটো LED রিং, আর একটা মাইক্রোফোন। |
Astrobee (NASA)
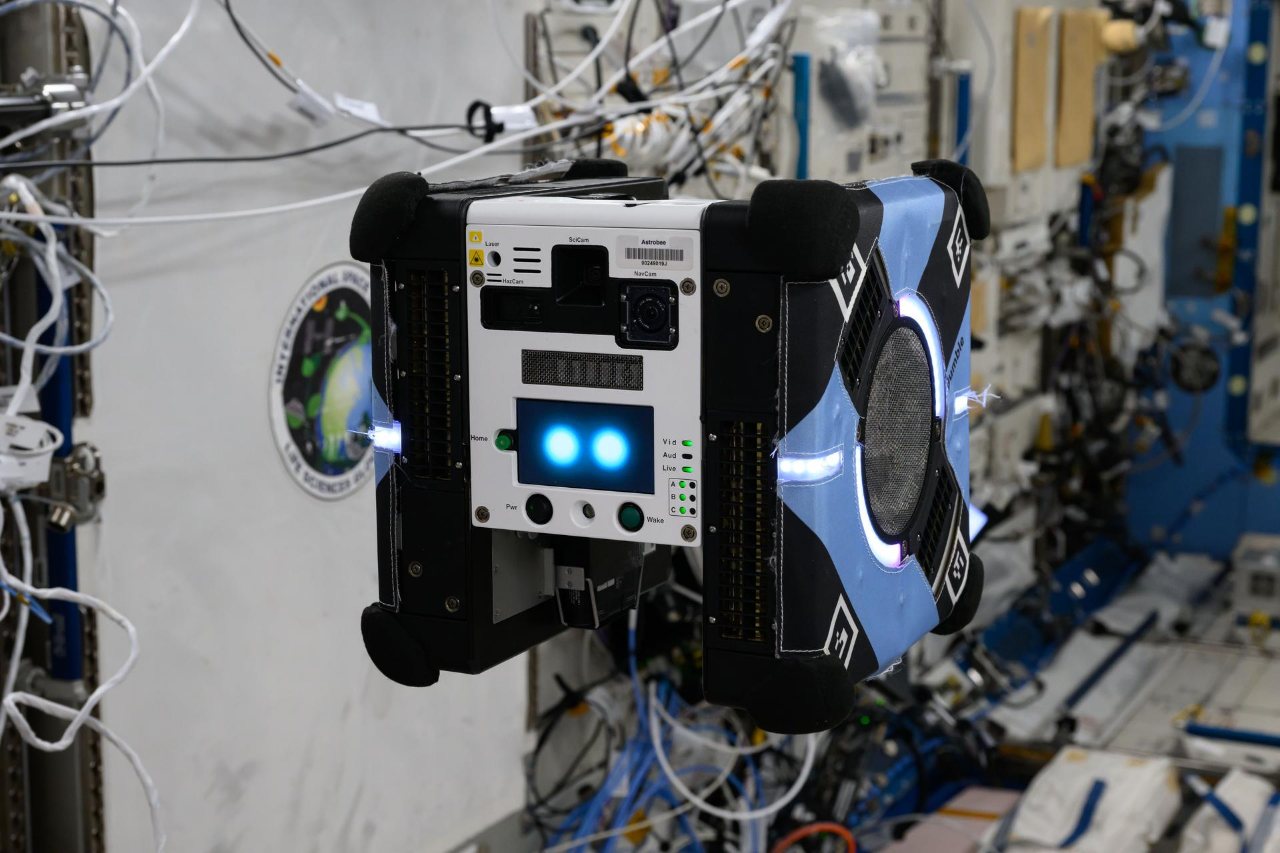
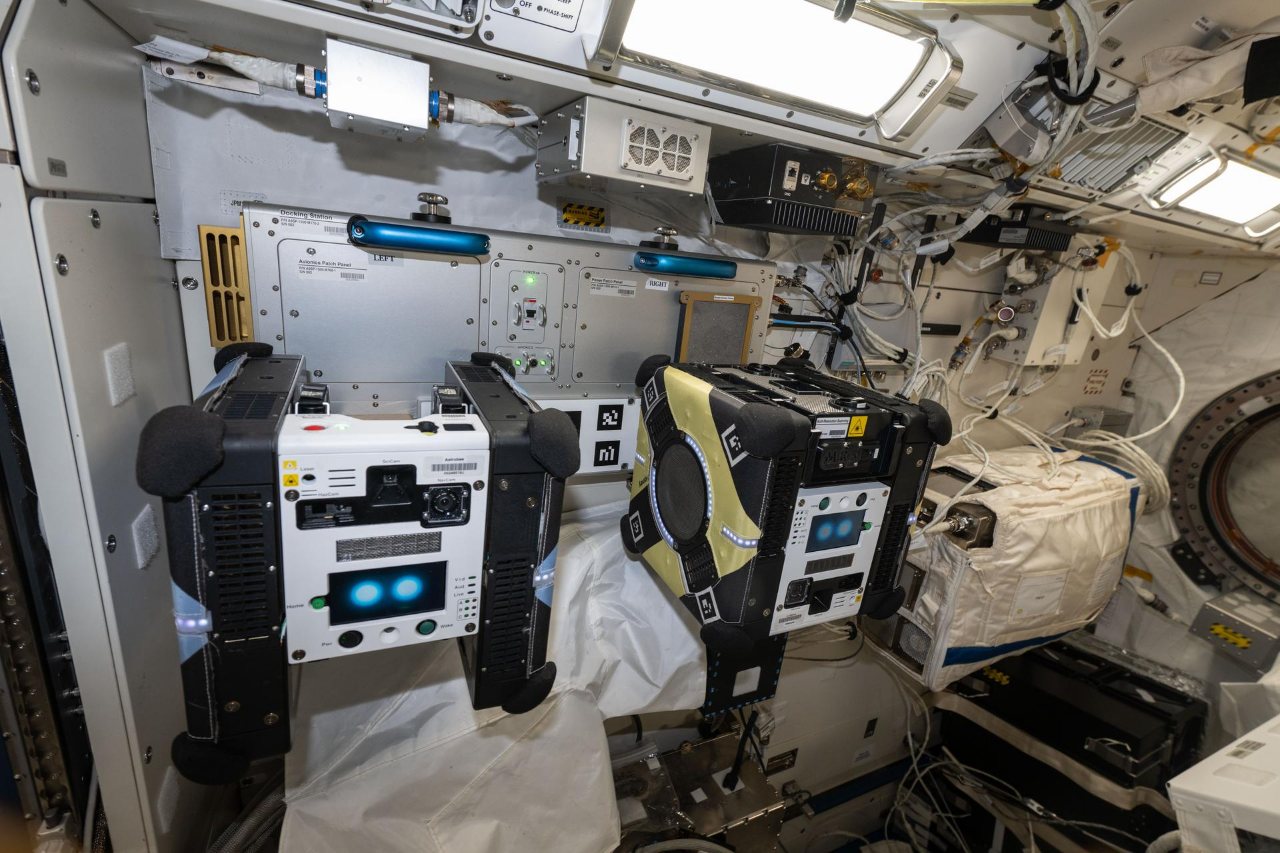
Astrobee হলো NASA-র ঘনকের মতো দেখতে উড়ুক্কু রোবট। Bumble, Honey আর Queen নামের তিনটা Astrobee ২০১৯ সাল থেকে ISS-এর ভেতরে উড়ছে। এরা ক্রুদের কাজের ভিডিও করে, পরীক্ষার যন্ত্রপাতি বয়ে বেড়ায় আর জরিপ করে; ১ম থেকে ৬ষ্ঠ Kibo-RPC-র রোবটও ছিল এরাই।
সামনে
পেছনে
| আকার | ৩২ সেমি (১২.৫ ইঞ্চি) চওড়া একটা ঘনক, কোণে নরম বাম্পার |
|---|---|
| ভর | প্রায় ১০ কেজি |
| চলে যা দিয়ে | পাশের দুটো মডিউল, প্রতিটায় একটা পাখা (ইমপেলার), যেটা মডিউলটাকে বাতাসে ভরে রাখে। নাড়ানো যায় এমন ১২টা নজল দিয়ে বাতাস বেরোয়, তাই এটা যেকোনো দিকে ঠেলতে আর ঘুরতে পারে (৬ ডিগ্রি অব ফ্রিডম)। |
| ঠেলা | সামনে বা পেছনে অন্তত ০.৬ N, আর অন্য দিকগুলোতে ০.৩ N (নকশার শর্ত)। |
| ক্যামেরা | ছয়টা: NavCam (ওয়াইড অ্যাঙ্গেল, পথ চেনার জন্য), SciCam (HD ভিডিও), HazCam (গভীরতা মাপে, বাধা এড়াতে), SpeedCam (গতি মাপে), DockCam (ডকের AR মার্কার খোঁজে) আর PerchCam (গভীরতা মাপে, হাতল খোঁজে)। |
| নিজের অবস্থান বোঝে | NavCam যা দেখে, তা ISS-এর একটা ম্যাপের সঙ্গে মিলিয়ে; সঙ্গে IMU, গভীরতার ক্যামেরা আর SpeedCam। |
| মস্তিষ্ক | তিনটা কম্পিউটার: লো-, মিড- আর হাই-লেভেল প্রসেসর (LLP, MLP, HLP)। HLP-তে চলে Android, আর গেস্ট-সায়েন্স অ্যাপগুলো চলে সেখানেই। |
| হাত আর যন্ত্রপাতি | গ্রিপারওয়ালা দুই জোড়ের একটা পার্চিং আর্ম হাতল আঁকড়ে ধরে, যাতে রোবট স্থির থাকতে আর শক্তি বাঁচাতে পারে। তিনটা পেলোড বে-তে পরীক্ষার যন্ত্রপাতি বসানো যায়। |
| শক্তি | সর্বোচ্চ চারটা ব্যাটারি, মোটামুটি ২ ঘণ্টা ওড়ার মতো; রিচার্জ করতে নিজেই ডকে গিয়ে বসে। |
| মানুষের সঙ্গে | টাচ স্ক্রিন, স্পিকার আর মাইক্রোফোন, সংকেত বাতি, লেজার পয়েন্টার আর টর্চ। |
পাশাপাশি তুলনা
| Int-Ball2 | Astrobee | |
|---|---|---|
| কোথাকার | JAXA (জাপান) | NASA (যুক্তরাষ্ট্র) |
| ISS-এ আছে | ২০২৩ থেকে, Kibo-তে | ২০১৯ থেকে, তিনটা রোবট |
| আকৃতি, আকার | বল, প্রায় ২০ সেমি | ঘনক, ৩২ সেমি |
| ভর | প্রায় ৩.৩ কেজি | প্রায় ১০ কেজি |
| ওড়ে যা দিয়ে | ৮টা প্রপেলার | ২টা পাখা আর ১২টা নজল |
| ক্যামেরা | ২টা (মূল আর স্টেরিও) | ৬টা |
| নিজেকে খুঁজে পায় | স্টেরিও ভিজ্যুয়াল SLAM আর IMU দিয়ে | NavCam-এর ম্যাপ মেলানো, IMU, গভীরতা আর গতির সেন্সর দিয়ে |
| কিছু ধরতে পারে | না | পার্চিং আর্ম দিয়ে |
| কম্পিউটার | NVIDIA Jetson TX2 | তিনটা প্রসেসর (একটায় চলে Android) |
| Kibo-RPC | ৭ম | ১ম থেকে ৬ষ্ঠ |
| ওপেন সোর্স | jaxa/int-ball2_simulator | nasa/astrobee |
৫ম Kibo-RPC-র ফাইনালে Int-Ball2 Astrobee-র রানগুলোর ভিডিও করেছিল: সেবারই প্রথম দুটো রোবট একসঙ্গে উড়েছিল (JAXA-র খবর)।
তোমার প্রোগ্রামের জন্য এর মানে কী
/sensor_fusion/navigation-এর মতো) রোবটের প্রোগ্রামের কমান্ডের নাম; এগুলোর মানে আছে নিয়মের গাইডে।- মার্কার পড়বে মূল ক্যামেরা দিয়ে। এটা সোজা সামনের দিকে তাকায়, কেন্দ্র থেকে ০.১৪ মি সামনে বসানো (প্রোগ্রামিং ম্যানুয়াল আর স্যান্ডবক্সেও একই সংখ্যা)। মার্কারের দিকে মুখ করাতে রোবটকে ঘোরাও; এটা পাশে বা পেছনে দেখতে পায় না।
- “আমি কোথায়”, সেটা একটা আন্দাজ মাত্র।
/sensor_fusion/navigationআসে স্টেরিও ক্যামেরা আর IMU থেকে। AR মার্কার পড়লে বোঝা যায় ক্যামেরার তুলনায় মার্কারটা আসলে কোথায় আছে, তাই বিচার চাওয়ার আগে এটা দিয়ে মিলিয়ে নাও। - ঠেলা খুব সামান্য। ৩.৩ কেজির রোবটে সর্বোচ্চ ১৫৫ mN ঠেলা মানে প্রতি সেকেন্ডে গতি বাড়ে বড়জোর সেকেন্ডে ৫ সেন্টিমিটার করে (ত্বরণ ০.০৫ মি/সে²-এর কম)। লম্বা ঘুরপথে সময় নষ্ট হয়, আর থেমে স্থির হতে রোবটের একটু সময় লাগে:
/event/checkpoint_passedচাওয়ার আগে একটু অপেক্ষা করো। - এটা আসল মডিউলে আসল যন্ত্র। যে প্রোগ্রাম আটকে যায় বা জিনিসপত্রে ধাক্কা খায়, তার রান নষ্ট হয়; এ কারণেই ফাইনালের আগে JAXA কোড যাচাই করে।
এরপর কী? শেখার পথের পরের ধাপ স্থানাঙ্ক ও ঘূর্ণন: রোবট কোথায় আর কোন দিকে মুখ করে, তা সংখ্যায় লেখা শেখো। চাইলে আগে মুক্ত ফ্লাইটে রোবটটা নিজে উড়িয়েও দেখতে পারো। স্যান্ডবক্সের ক্যামেরাও কেন্দ্র থেকে ০.১৪ মি সামনে, ঠিক Int-Ball2-এর মূল ক্যামেরার মতো।
শব্দকোষ
- ISS
- আন্তর্জাতিক মহাকাশ স্টেশন। (অংশ ১)
- Kibo
- ISS-এ জাপানের মডিউল (ঘর); রোবট এর ভেতরে ওড়ে। (অংশ ১)
- মাইক্রোগ্র্যাভিটি
- প্রায় শূন্য মাধ্যাকর্ষণ: সবকিছু ভেসে থাকে। (অংশ ২)
- প্রপেলার / পাখা
- বাতাস ঠেলে রোবটকে উল্টো দিকে সরায়। (অংশ ২)
- IMU
- যে সেন্সর রোবটের ঘোরা আর গতি বদলানো টের পায়। (অংশ ৩)
- স্টেরিও ক্যামেরা
- পাশাপাশি দুটো ক্যামেরা, দূরত্ব বোঝার জন্য। (অংশ ৩)
- SLAM
- ম্যাপ বানানো আর একই সঙ্গে সেই ম্যাপে নিজেকে খুঁজে নেওয়া। (অংশ ৩)
- AR মার্কার
- QR কোডের মতো সাদাকালো চৌকো ছবি, যাতে একটা নম্বর লুকানো থাকে। (অংশ ৩)
- ডকিং স্টেশন
- রোবটের “বাসা”: এখানে বসে সে চার্জ নেয়, খেলাও এখান থেকে শুরু।
1. The space station and Kibo
The International Space Station (ISS) circles the Earth about 400 kilometres up: if you could drive straight up on a motorway, you'd get there in about four hours. It goes all the way round the Earth in about an hour and a half.
Astronauts live inside it and do science experiments. The station is made of many rooms joined together; each room is called a module. Japan's module is called Kibo (Japanese for "hope"): a long room shaped like a tube, with about as much space inside as a bus. That's where the robot flies.
- ISS
- The International Space Station.
- module
- One of the station's rooms. Kibo is Japan's module.
- astronaut
- A person who travels to space.
2. How a floating robot moves
Inside the station everything floats: pens, drops of water, people too. That's because the station and everything inside it are all "falling" around the Earth together, none faster than the others, so nothing seems to weigh anything. This is called microgravity (almost no gravity).
So how does the robot move? Wheels are no use, because a floating robot doesn't even touch the floor! Think of a balloon: blow it up and let go, and the air rushes out of the back while the balloon shoots forward.
Int-Ball2 does the same: small fans inside it push air one way, and the robot moves the other way. By running different fans, it can move and turn in any direction.
Here's a strange thing: once it starts moving, the robot hardly slows down by itself; to stop, it has to push the other way. Turn on Zero-g on the Free flight page and feel it for yourself!
Why can't a robot with wheels move around the space station?
Wheels move by pushing against the floor. A floating robot doesn't touch the floor, so the wheels would just spin in the air.
To move the robot to the left, which way do the fans push the air?
To the right. The robot always goes the opposite way to the air.
3. How the robot sees and finds its way
If you walk round a room with your eyes shut, you guess how far you've walked and turned. When you open your eyes, you look at things you know (the board, the windows) to check exactly where you are. Int-Ball2 works out where it is in just the same way:
- IMU (guessing with your eyes shut): a tiny sensor that feels how much the robot turns and how hard it speeds up or slows down. It's a bit like the part inside your ear that keeps your balance.
- Stereo camera (opening your eyes): two cameras side by side, like your two eyes. With two eyes you can tell how far away things are. The robot uses them to make a map of the module and find itself on that map.
- Main camera: the camera at the front that takes photos and video. In Kibo-RPC, this is the one that reads the AR markers.
An AR marker is a black-and-white square picture, a bit like a QR code. Each one hides a number (its ID), and from the camera picture you can work out how far away the marker is and which way it faces. Kibo has 12 of these inside it.
Using the IMU and the stereo camera together, the robot always knows where it is and which way it faces. How "where" and "which way" are written as numbers is the next step on the learning path: Coordinates and rotations.
What does the IMU feel?
How much the robot turns, and how hard it speeds up or slows down.
Why is it useful to have two cameras side by side?
They show how far away things are, just like our two eyes.
Which camera reads the AR markers in Kibo-RPC?
The main camera, at the front of the robot.
Int-Ball2 (JAXA)
Int-Ball2 (JEM Internal Ball Camera 2) is a ball-shaped flying camera robot, about the size of a football, that has worked inside Kibo since June 2023. Ground controllers fly it to take photos and video, so astronauts spend less time holding cameras. It can also run programs written by other teams, which is how Kibo-RPC 7 programs reach orbit.
Front
Back
| Size | A ball about 20 cm across |
|---|---|
| Mass | About 3.3 kg |
| Moves with | 8 small propellers in ducts, pointing out at angles; half spin clockwise, half anticlockwise. Together they push and turn it in any direction (this is called 6 degrees of freedom: moving three ways, and turning three ways). |
| Strongest push | 155 mN forward or back, 95 mN up or down, 57 mN sideways (measured; mN, millinewtons, measure force). That's about what a 16 g object weighs on Earth, about three sheets of A4 paper, so it speeds up and stops gently. |
| Cameras | Main camera at the front for photos and video. Stereo camera (two lenses) for navigation. |
| Knows where it is by | (in simple words in part 3) Visual SLAM on the stereo camera (it maps the module and finds itself in the map), combined with an IMU (an Epson inertial measurement unit: gyroscopes and accelerometers). |
| Brain | An NVIDIA Jetson TX2 running Linux and ROS. User programs run in Docker containers, separate from the flight software. |
| Power | A rechargeable battery; it docks itself on its docking station to charge. |
| With people | Two LED rings that show its state, and a microphone. |
Astrobee (NASA)
Astrobee is NASA's cube-shaped free-flyer. Three of them, named Bumble, Honey and Queen, have flown inside the ISS since 2019. They film crew work, carry experiments and take surveys, and they were the robots of the 1st to 6th Kibo-RPC.
Front
Back
| Size | A cube 32 cm (12.5 inches) wide, with soft corner bumpers |
|---|---|
| Mass | About 10 kg |
| Moves with | Two side modules, each with a fan (impeller) that fills it with air. 12 adjustable nozzles let the air out, so it can push and turn in any direction (6 degrees of freedom). |
| Push | At least 0.6 N forward or back and 0.3 N in the other directions (the design requirement). |
| Cameras | Six: NavCam (wide angle, for navigation), SciCam (HD video), HazCam (depth, for obstacles), SpeedCam (measures speed), DockCam (finds the AR markers on its dock) and PerchCam (depth, finds handrails). |
| Knows where it is by | Matching what the NavCam sees to a map of the ISS, combined with an IMU, its depth cameras and the SpeedCam. |
| Brain | Three computers: low-, mid- and high-level processors (LLP, MLP, HLP). The HLP runs Android, and guest-science apps run there. |
| Arm and payloads | A two-joint perching arm with a gripper grabs handrails, so it can hold still and save power. Three payload bays carry experiment hardware. |
| Power | Up to four batteries, about 2 hours of flying; it docks itself to recharge. |
| With people | Touch screen, speaker and microphone, signal lights, laser pointer and flashlights. |
Side by side
| Int-Ball2 | Astrobee | |
|---|---|---|
| From | JAXA (Japan) | NASA (USA) |
| On the ISS since | 2023, in Kibo | 2019, three robots |
| Shape, size | Ball, about 20 cm | Cube, 32 cm |
| Mass | About 3.3 kg | About 10 kg |
| Flies with | 8 propellers | 2 fans and 12 nozzles |
| Cameras | 2 (main and stereo) | 6 |
| Finds itself with | Stereo Visual SLAM and an IMU | NavCam map matching, IMU, depth and speed sensors |
| Grabs things | No | Perching arm |
| Computer | NVIDIA Jetson TX2 | Three processors (one runs Android) |
| Kibo-RPC | 7th | 1st to 6th |
| Open source | jaxa/int-ball2_simulator | nasa/astrobee |
In the 5th Kibo-RPC final, Int-Ball2 filmed Astrobee's runs: the first time the two robots flew together (JAXA news).
What this means for your program
/sensor_fusion/navigation) are names of commands in the robot's program; the rules guide explains them.- You read markers with the main camera. It looks straight out of the front, 0.14 m from the centre (the same number as in the Programming Manual and the sandbox). Turn the robot to face a marker; it can't see sideways or behind.
- "Where am I" is an estimate.
/sensor_fusion/navigationcomes from the stereo camera and the IMU. Reading the AR marker tells you how the marker really sits relative to the camera, so use it to check before you ask the judge. - The push is small. At most 155 mN on a 3.3 kg robot means its speed grows by no more than 5 centimetres per second, each second (under 0.05 m/s² of acceleration). Long detours cost time, and the robot needs a moment to stop and settle: wait before asking
/event/checkpoint_passed. - It's a real machine in a real module. A program that gets stuck or bumps into things loses the run, which is why JAXA reviews code before the final round.
What next? The next step on the learning path is Coordinates and rotations: how to write where the robot is and which way it faces as numbers. Or fly the robot yourself first in Free flight. The sandbox's camera also sits 0.14 m in front of the centre, just like Int-Ball2's main camera.
Word list
- ISS
- The International Space Station. (part 1)
- Kibo
- Japan's module (room) on the ISS; the robot flies inside it. (part 1)
- microgravity
- Almost no gravity: everything floats. (part 2)
- propeller / fan
- Pushes air so the robot moves the other way. (part 2)
- IMU
- The sensor that feels the robot turning and changing speed. (part 3)
- stereo camera
- Two cameras side by side, for judging distance. (part 3)
- SLAM
- Making a map and finding yourself on it at the same time. (part 3)
- AR marker
- A black-and-white square picture, like a QR code, with a number hidden in it. (part 3)
- docking station
- The robot's "home": it charges there, and every game starts there.